Integrators deliver more cells.
Fewer engineering hours on fixed-price projects.
For integrators
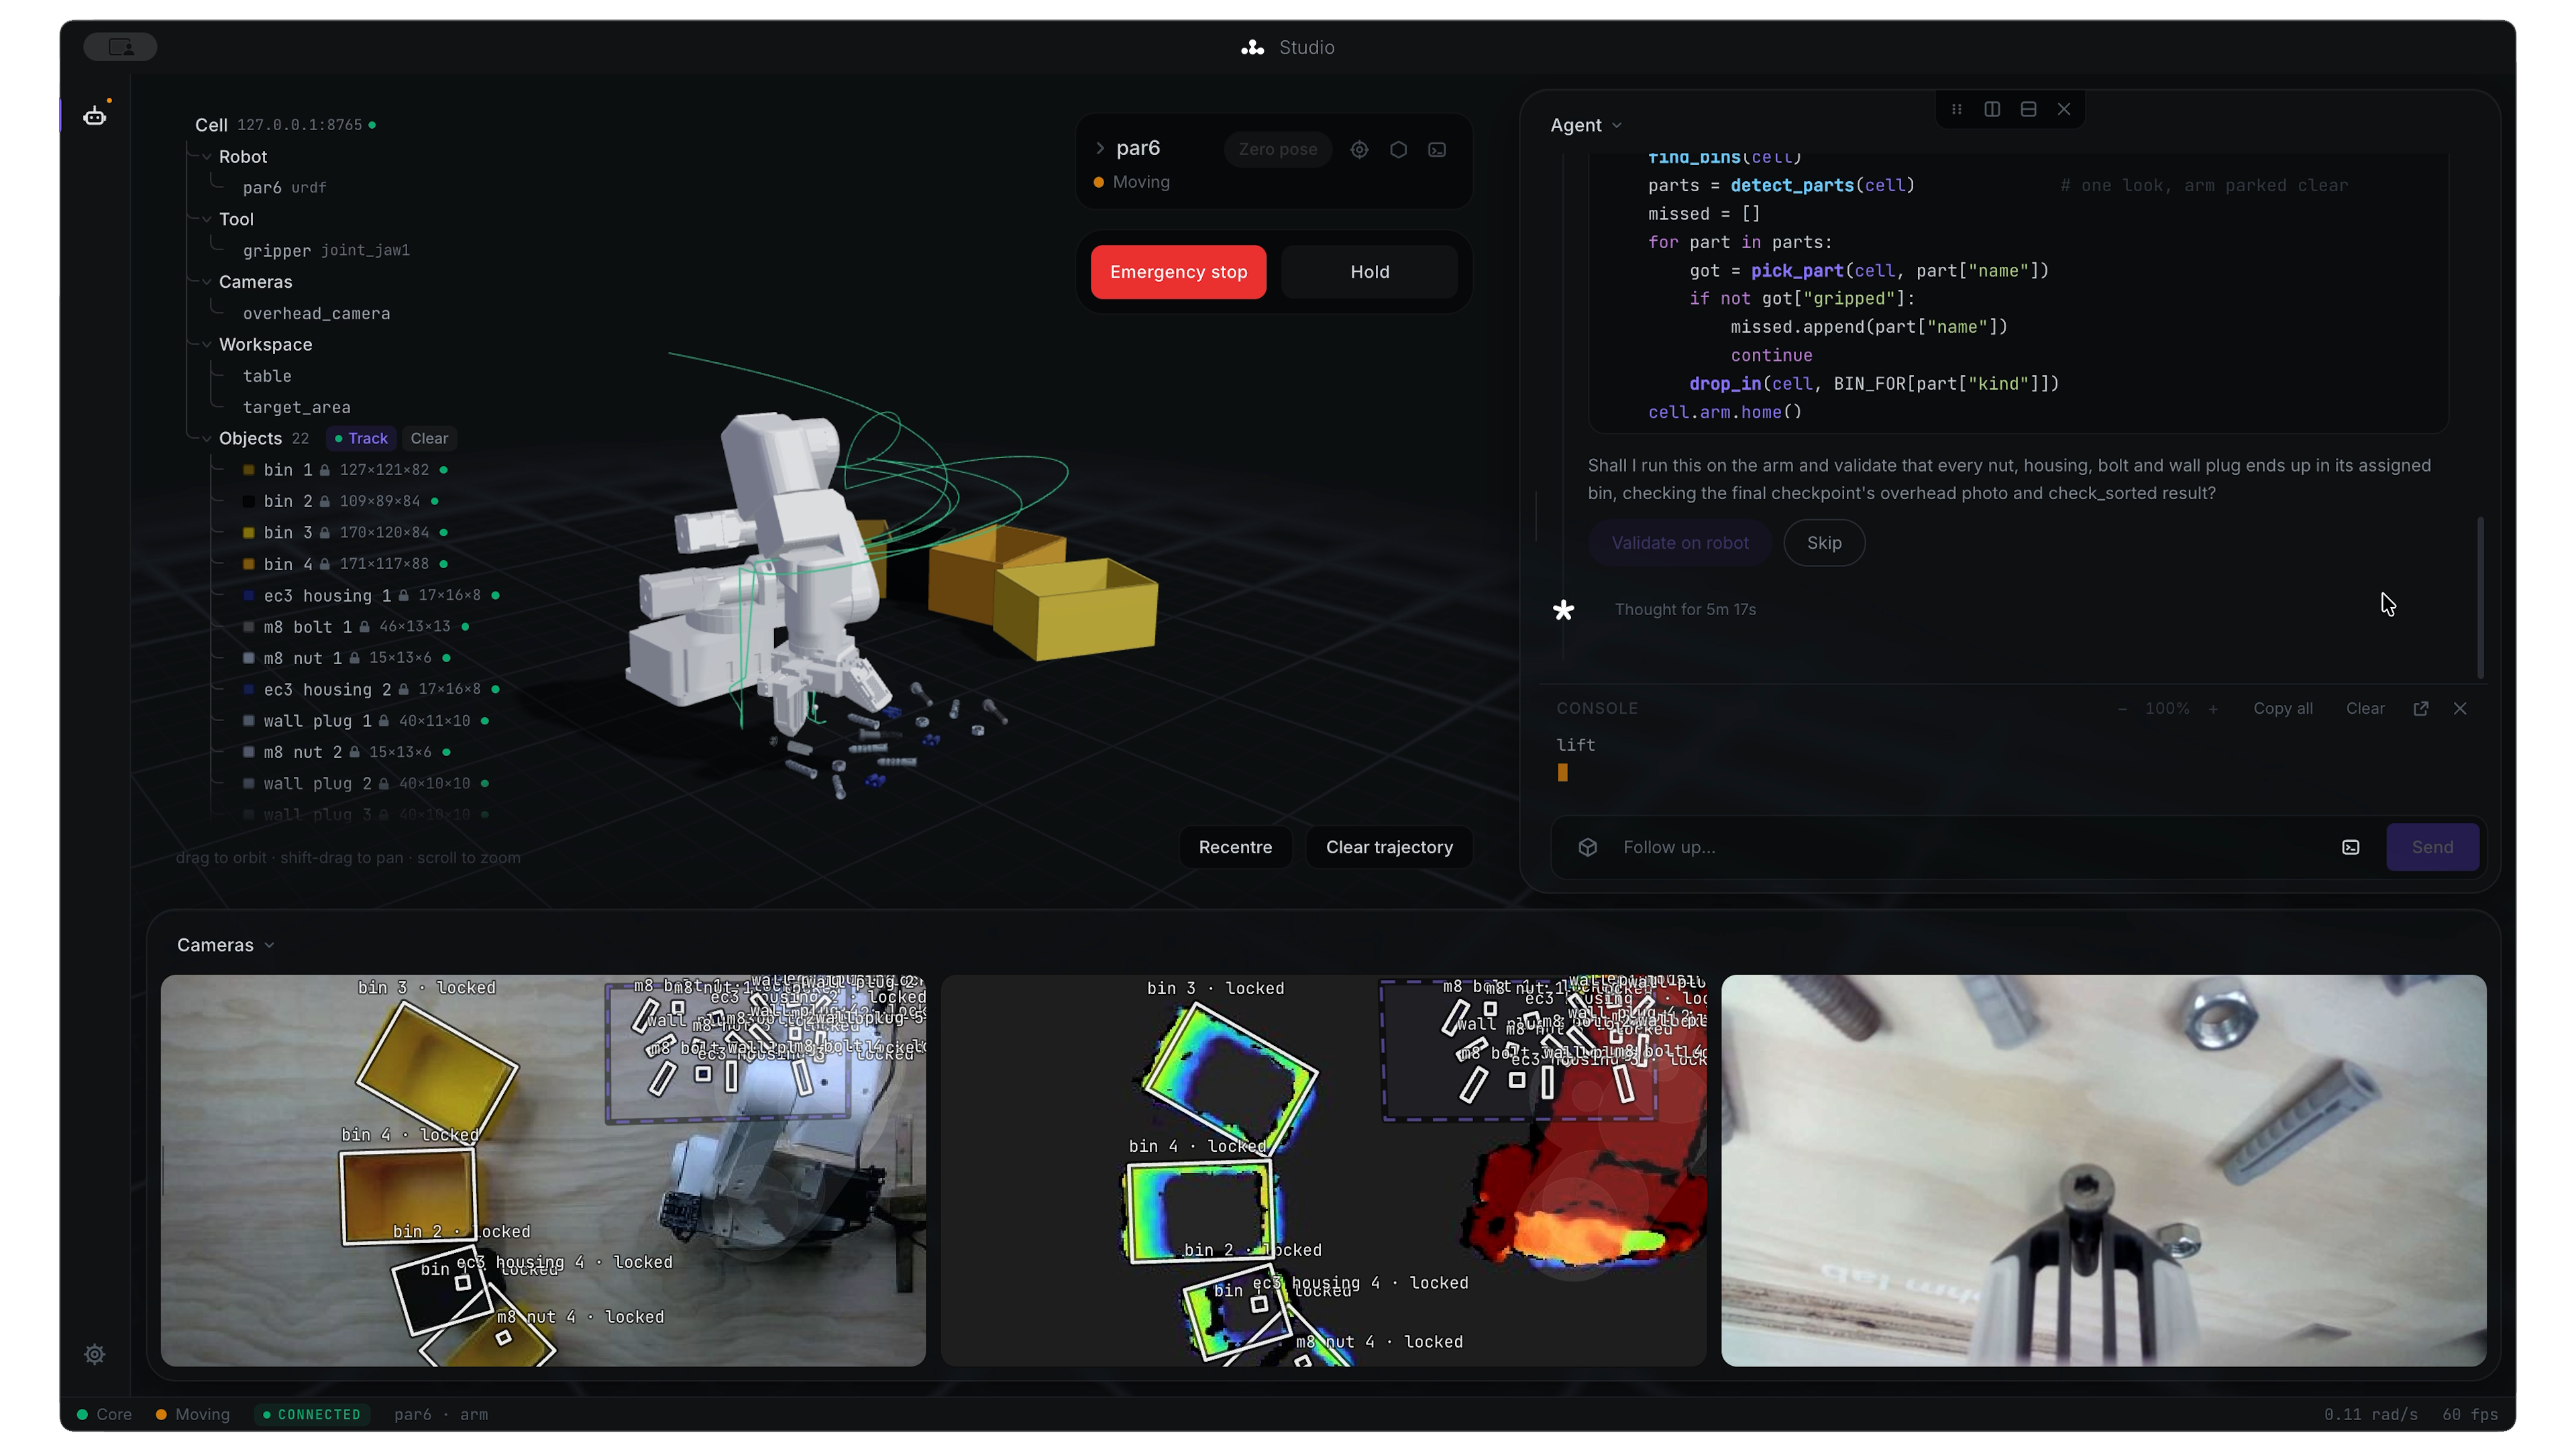
Ohm Lab Studio is a robotics engineering environment built for coding agents.
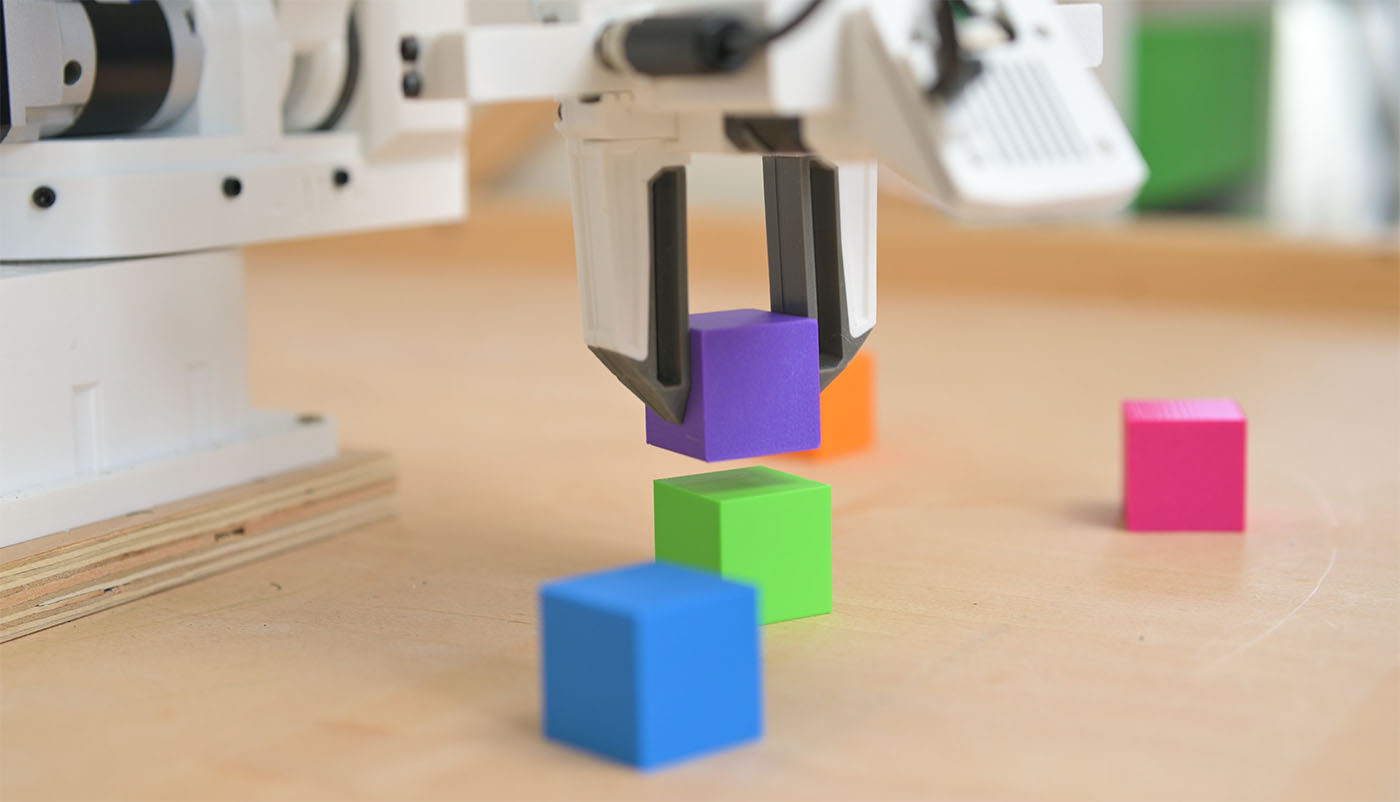
Our goal is to allow factory workers & manufacturing engineers to deploy & re-task robots on the shop floor, without calling out a robotics integrator.
And much of that engineering is repeated when a part, fixture or process changes.
In high-mix manufacturing, automation is often uneconomical.
It writes deterministic code from reusable skills and perception, validates it in a real-time digital twin, and deploys once an engineer approves.
The code runs in production without the agent in the loop.
Coding agents are great at software but struggle with physical machines. They struggle to perceive the cell or validate the robot's actions, rarely reach production-ready repeatability, and have no guardrails to protect the machinery or the people on the shop floor.
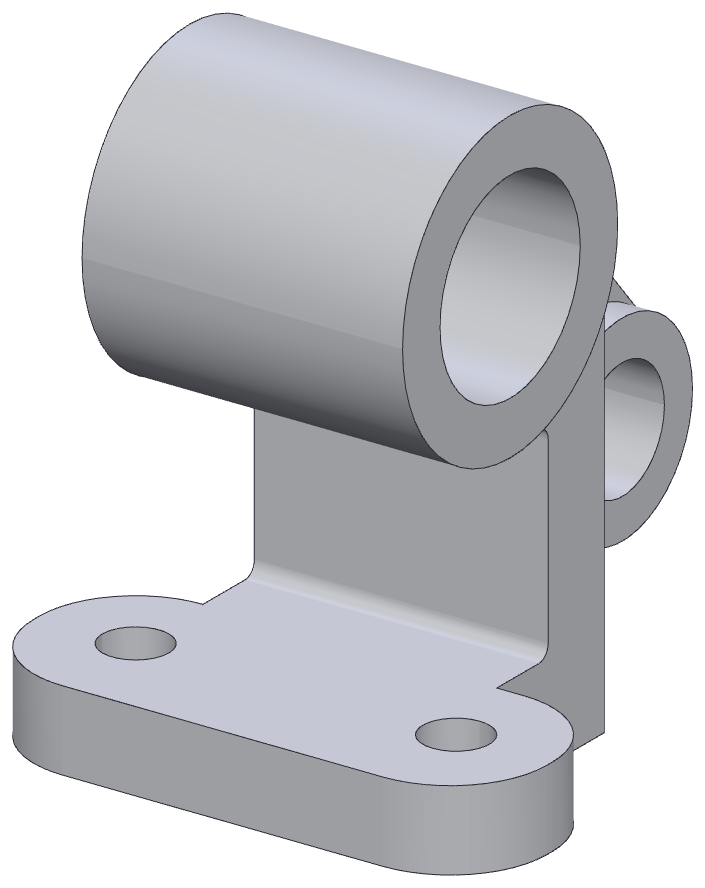
Our detection and pose models can be adapted to your part using synthetic images of its CAD file in under 30 seconds, reducing the time and effort to re-task your robot for different processes.
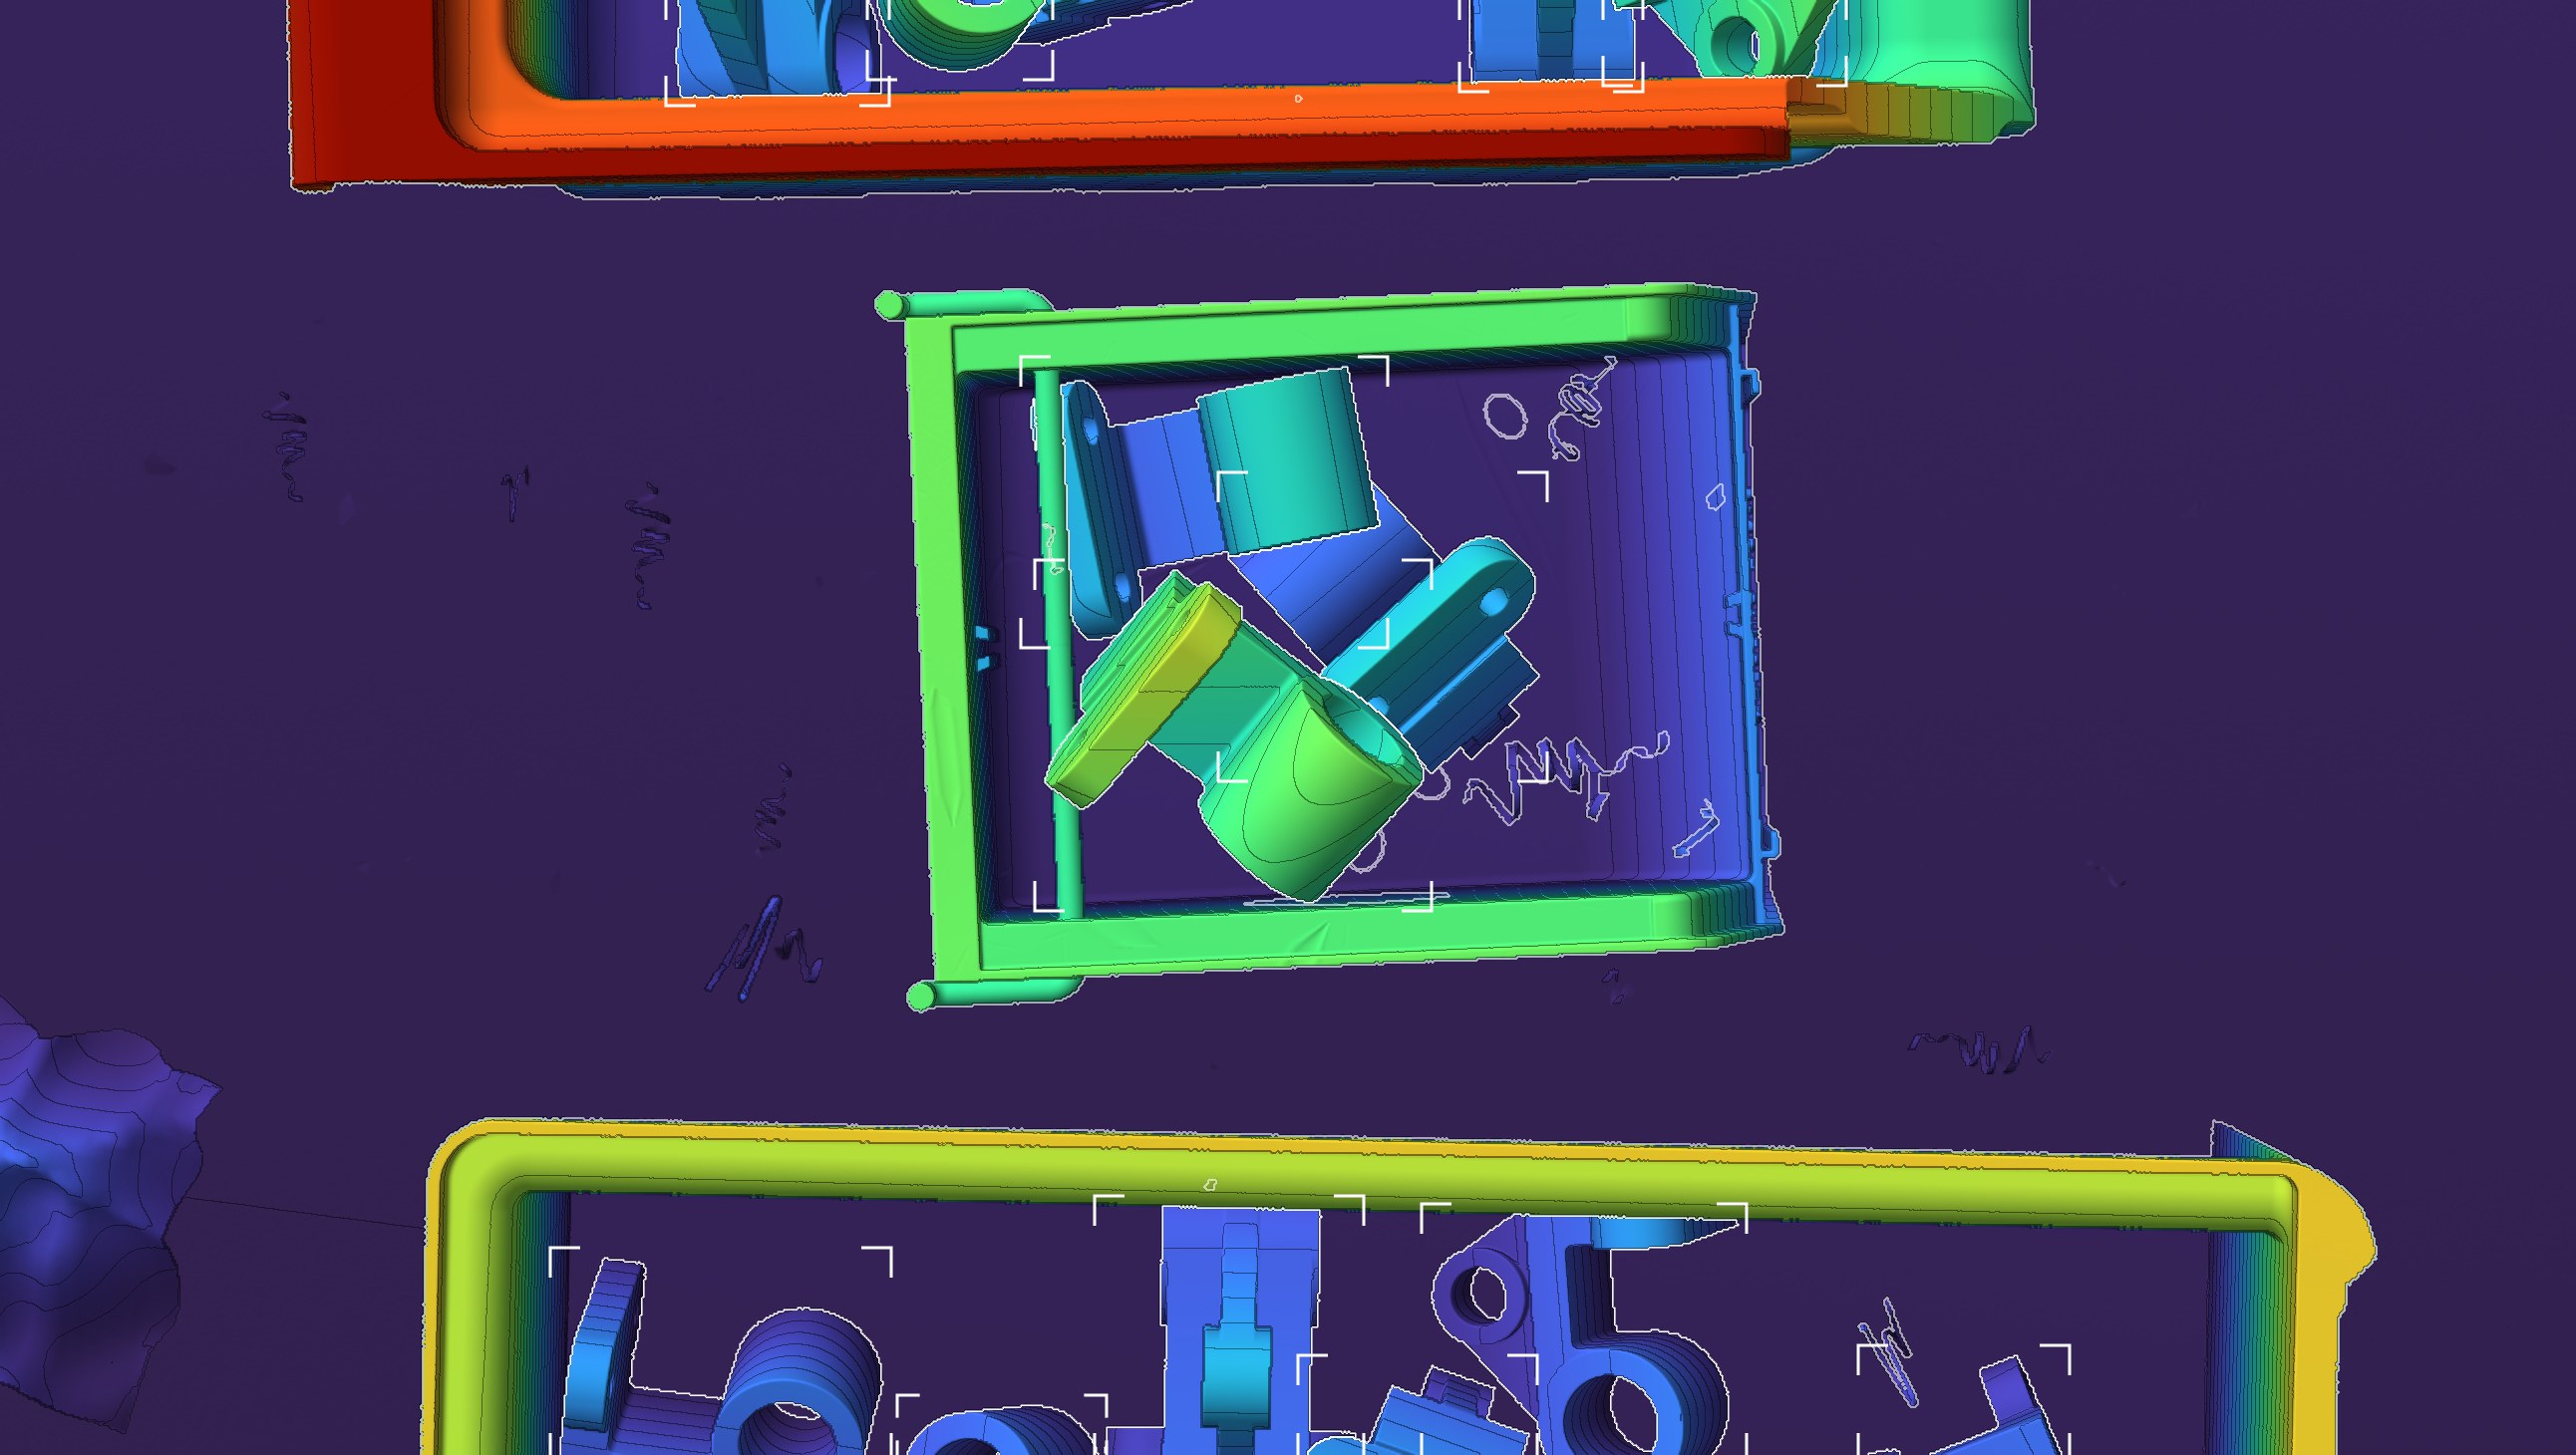
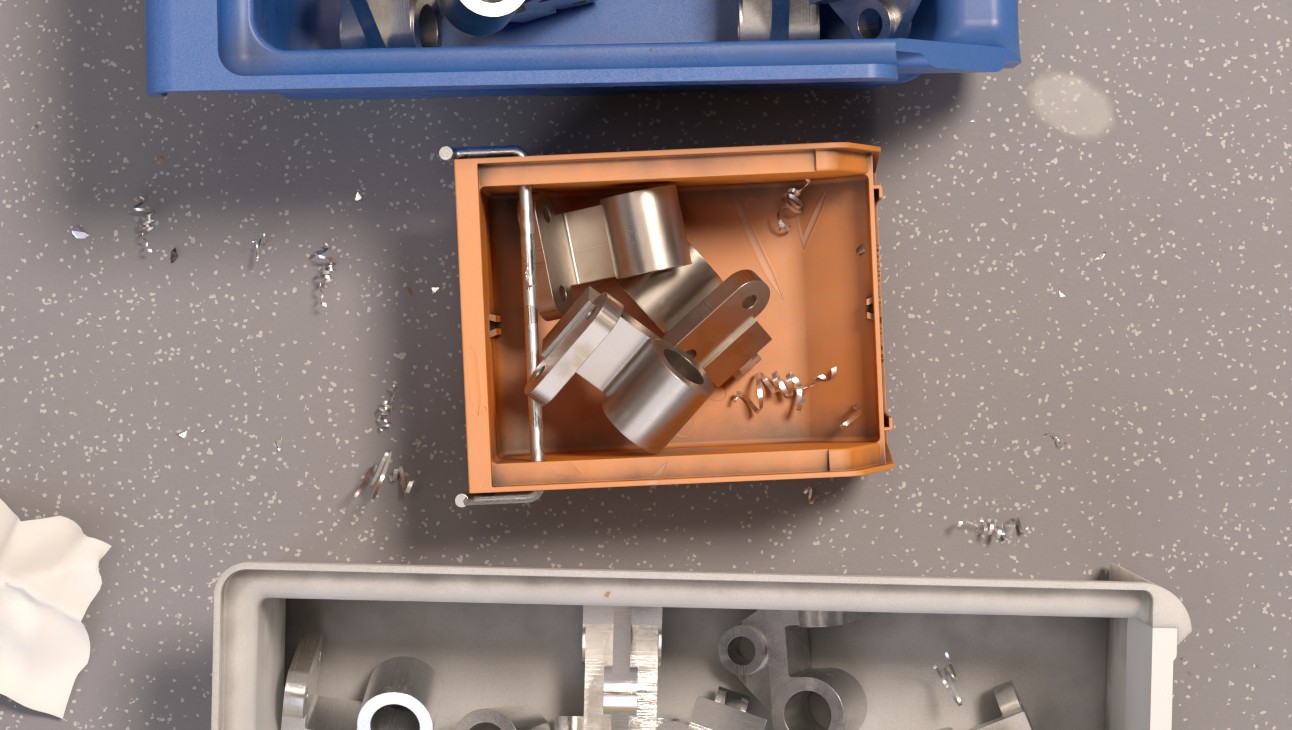
Ohm Lab Studio compounds real-world experience, building reusable skills from successes and guardrails from failures.
seePerception skillLooked over cell 3 and the new bracketdetect_partsPerception skillBracket is 40 mm wider than the last partpick_partReusable skillReused, with a wider grasp for the bracketclear_fixture_edgeGuardrailAdded after a clipped fixture on run 4drop_inReusable skillSorts each part into its assigned binslow_near_wallsGuardrailApproach speed capped near bin wallsThe agent writes Python code that interacts with your existing robot stack through Ohm Lab Studio's hardware adapters. Nothing runs on the robot until an engineer approves the code.
Once approved, it runs in production without the agent in the loop. Studio is designed to sit alongside your existing controller or PLC, and certified safety functions are unchanged.
sort_parts.py Awaiting approval
bins = find_bins(cell)
# one look, arm parked clear
parts = detect_parts(cell)
missed = []

for part in parts:
    got = pick_part(cell, part["name"])
    if not got["gripped"]:
        missed.append(part["name"])
        continue
    drop_in(cell, BIN_FOR[part["kind"]])

cell.arm.home()We gave the same AI model (Claude Sonnet 5.5), the same robots and software stack (ROS 2 and MoveIt), once with Ohm Lab Studio and once without, across eight tasks.
7.3×
faster on average
66%
fewer attempts on the robot
8 of 8
tasks completed, against 5 without Studio
Paired runs on two desktop arms, September 2026: five movement tasks and three pick-and-place, a fresh agent each run, a fixed time limit and no human intervention.
Fewer engineering hours on fixed-price projects.
New variants, fixtures and processes deployed by your existing engineers, no specialists required.
Got a manufacturing task you'd like to automate? Get in touch! We'd love to hear about it.